on
Zephyr Modern C++ - State Machine Size Comparison
Can we use the latest C++ features on microcontrollers? Yes.
I’ve been testing out to use it on Zephyr and ESP-IDF.
One particular feature I tried out in this example is the use of std::variant for different States, and ultimately using std::visit to iterate through them. Here I provide implementation of a general get_state_info to read what the current state is using the Overloaded Lambda idiom (to enforce availability of all StateVariants), it will then return a std::string_view of different messages based on the current_state_.
Let’s say, a more shiny StateMachine haha. A different approach than using bare enums and switch statements (not simply saying they are less).
Check it out! https://github.com/royyandzakiy/zephyr-modern-cpp
So far, there is a 540 bytes difference when using std::variant/std::visit, compared to raw enum/switch.
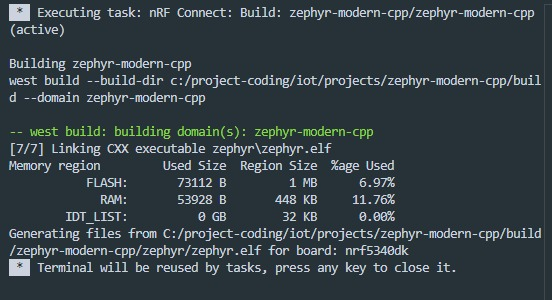
First build (std::variant/visit):
- FLASH: 73,112 bytes (6.97% of 1MB)
- RAM: 53,928 bytes (11.76% of 448KB)
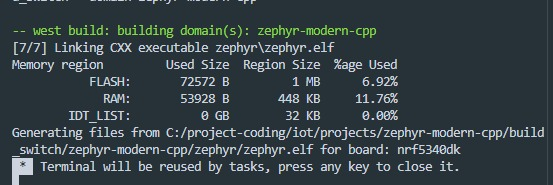
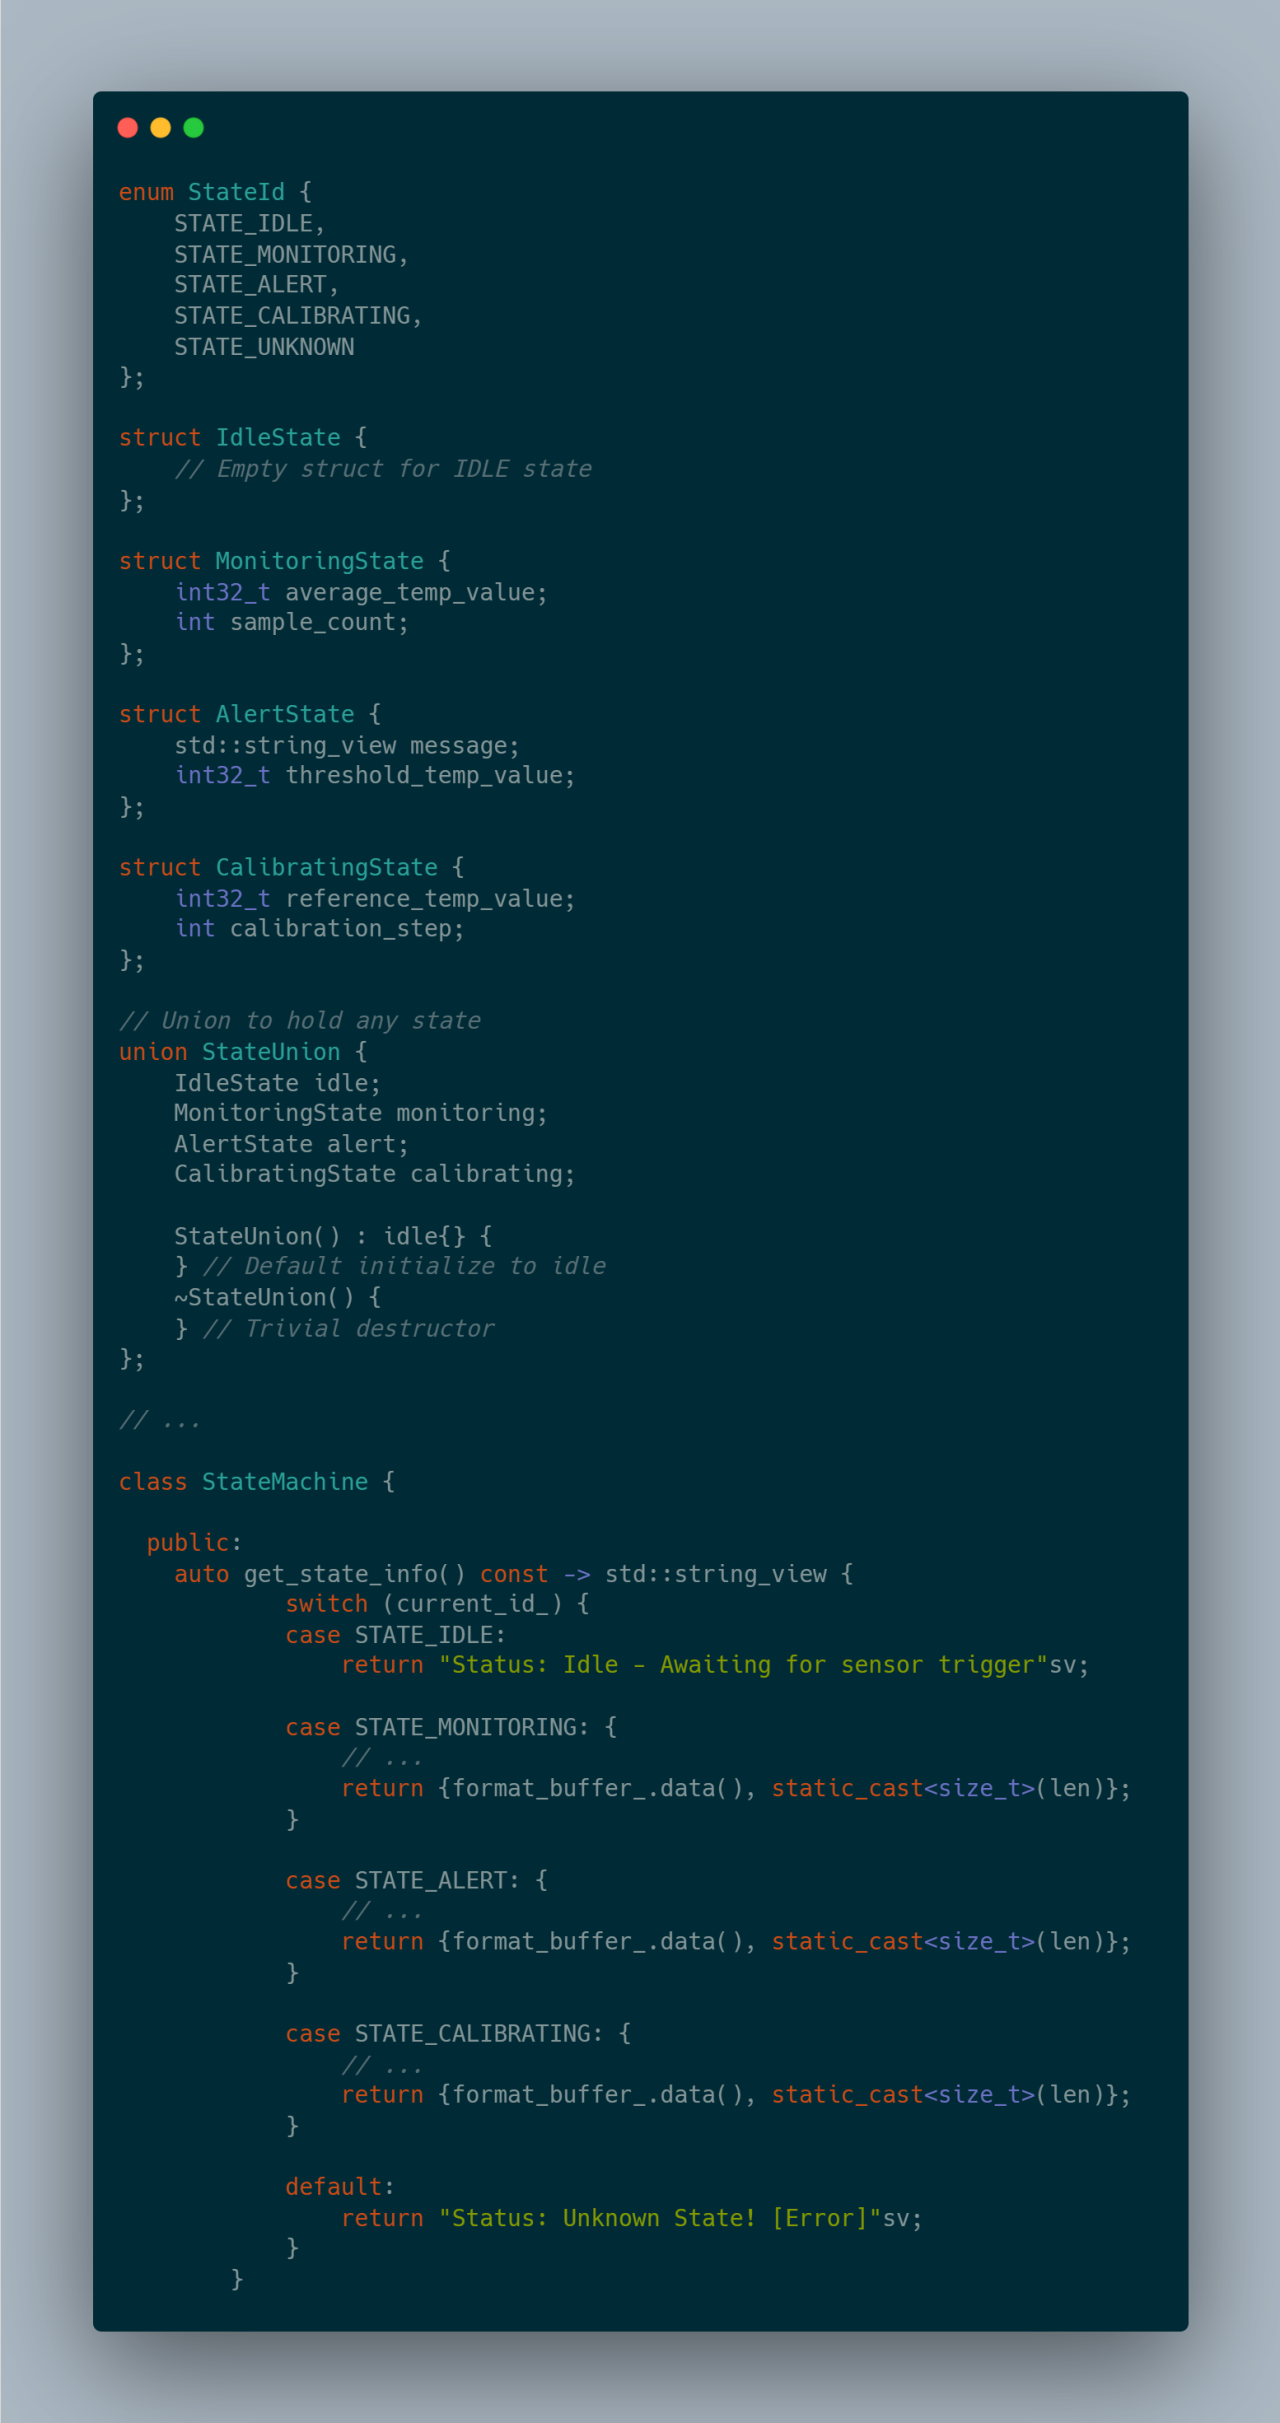
Second build (enum/switch) (code depicted in image below):
- FLASH: 72,572 bytes (6.92% of 1MB)
- RAM: 53,928 bytes (11.76% of 448KB)
I also tried comparing when adding the C++ library to the compilation, and removing it. There is a 4256 byte addition.
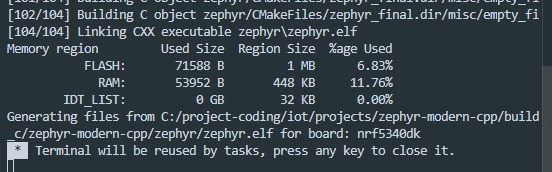
Third build (converting all C++ to pure C & but still compiling C++ library in kconfig):
- FLASH: 71,588 bytes (6.83% of 1MB)
- RAM: 53,952 bytes (11.76% of 448KB)
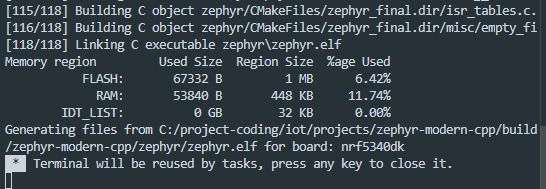
Fourth build (converting all C++ to pure C & removing C++ library in kconfig):
- FLASH: 67,332 bytes (6.42% of 1MB)
- RAM: 53,840 bytes (11.74% of 448KB)
State machine using std::variant, std::visit
State machine using enum & switch
Removing most all CPP code, change into C
Removing CPP lib in prj.conf
Code using enum & switch
The variant doesn’t add too much overhead. I was expecting a lot more bytes eaten up just by using Templates itself 😄
cc Srdjan Stokic
Discussion and feedback